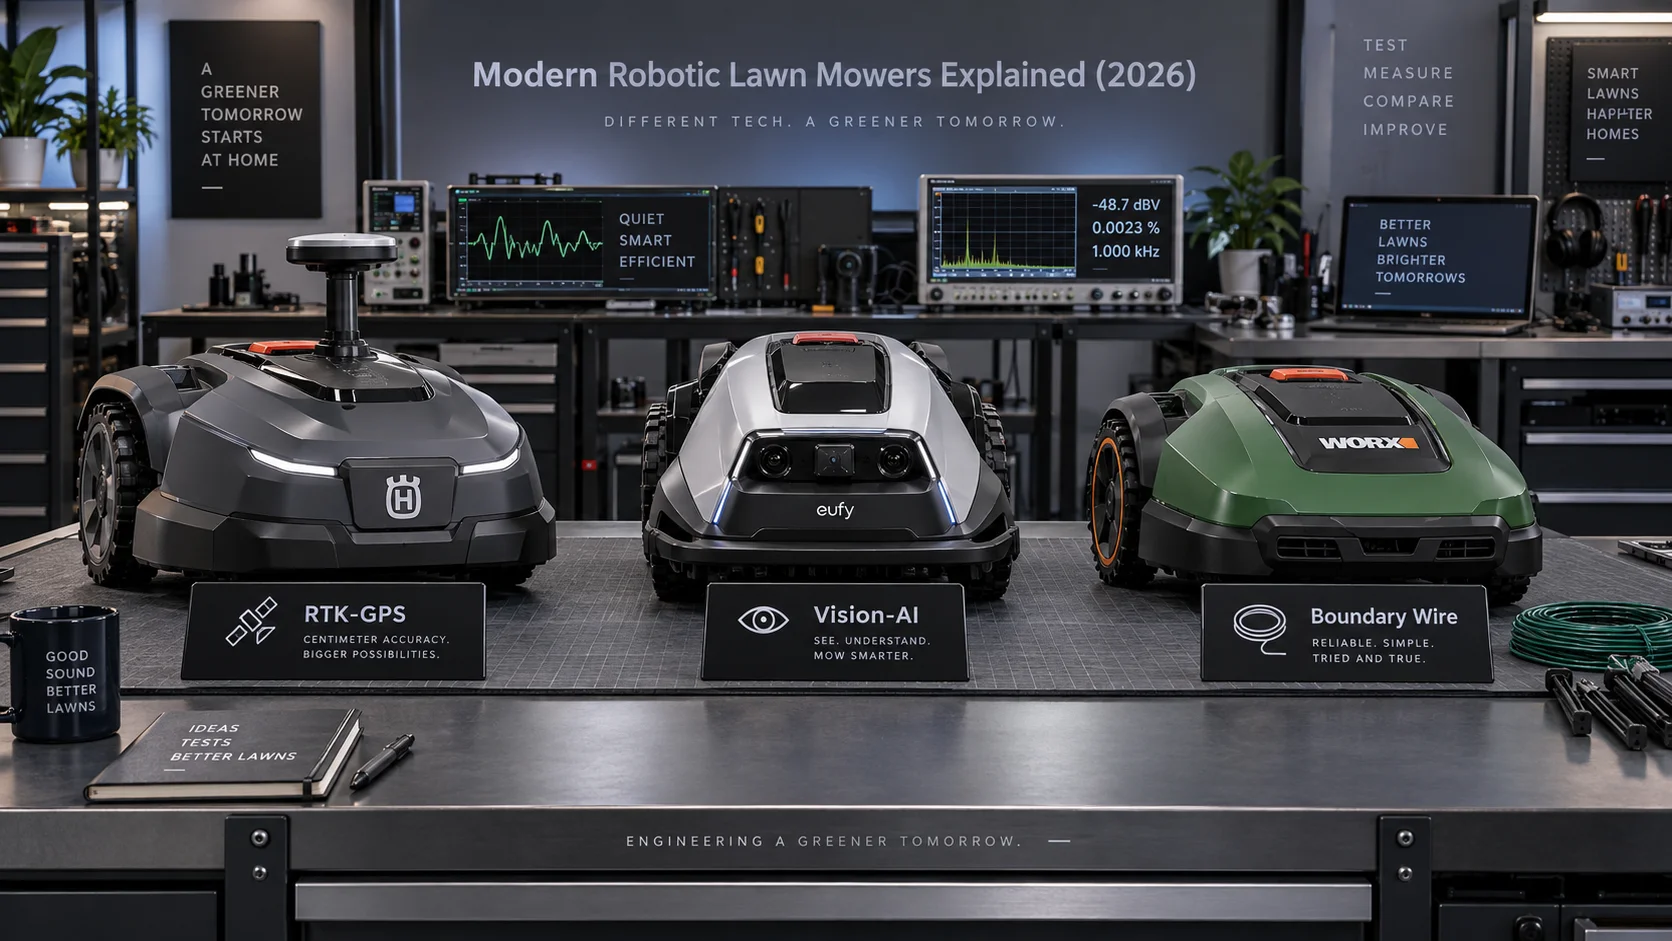
Understanding the Three Navigation Architectures
Modern robotic lawn mowers have evolved far beyond the “bump-and-turn” machines of a decade ago. Today’s flagship units navigate through one of three fundamentally different positioning systems: RTK-GPS (Real-Time Kinematic satellite positioning), Vision-AI (camera and neural-network-driven mapping), or legacy Boundary Wire (buried inductive loop). Each architecture affects not just purchase price, but installation effort, obstacle handling, mowing pattern quality, and long-term reliability. Before comparing models, it is worth understanding how each system actually works at the hardware level, because the differences are more architectural than cosmetic.
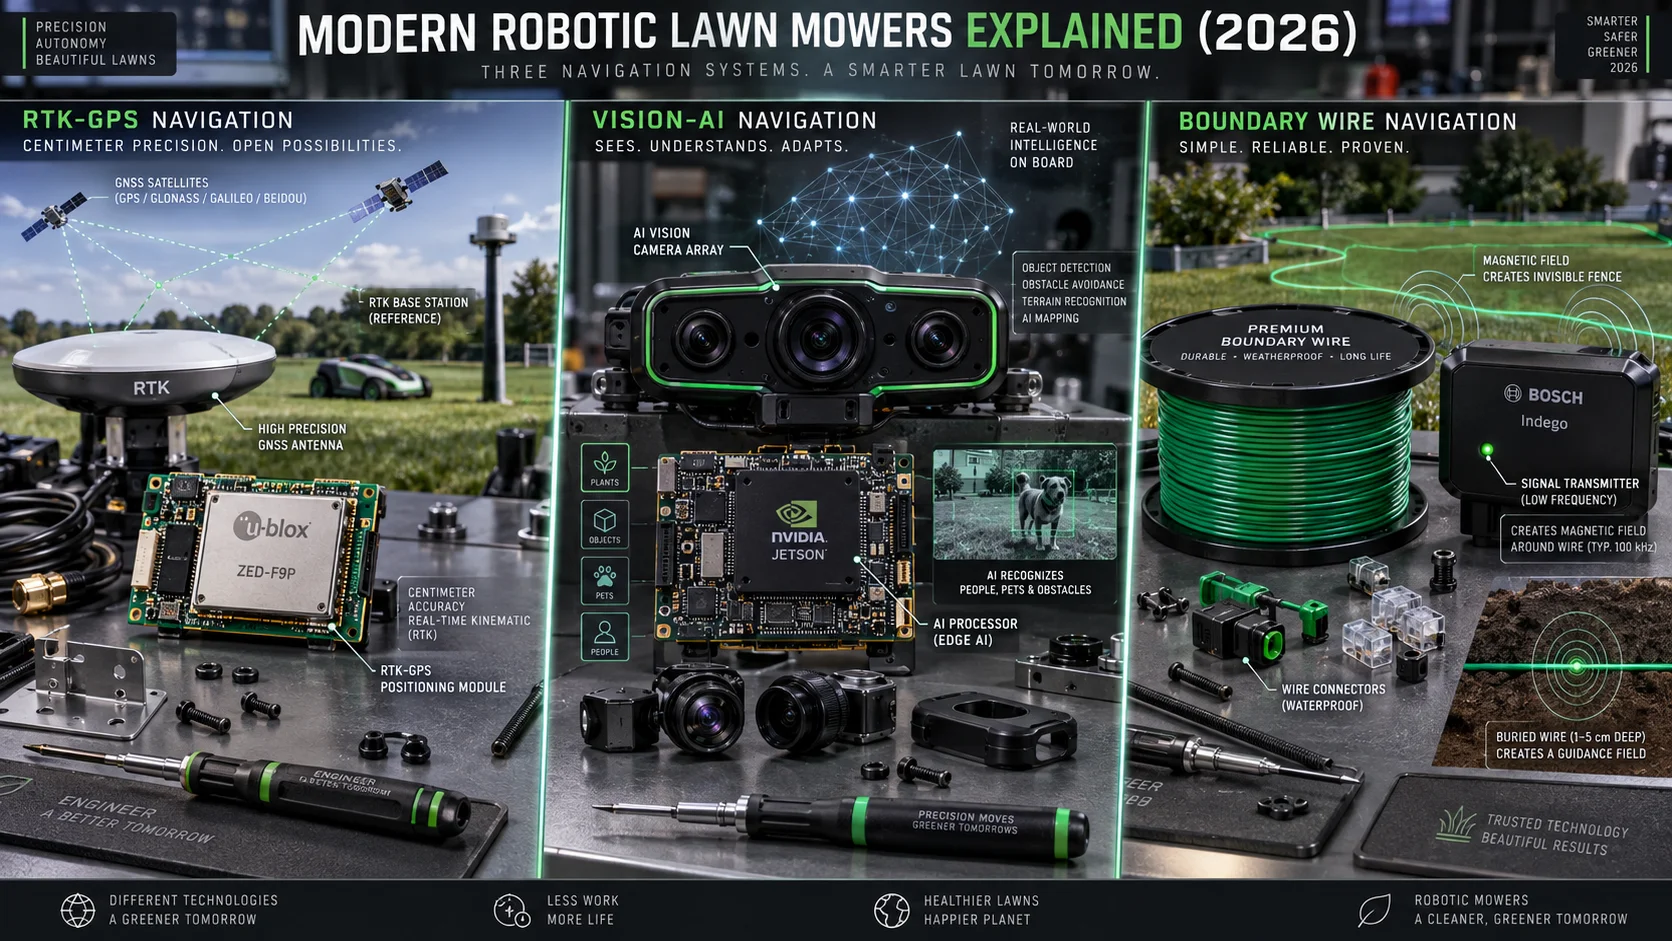
How RTK-GPS Mowers Work
RTK-GPS is a differential positioning technique that dramatically improves standard GPS accuracy. A standard consumer GPS receiver is accurate to roughly 2 to 5 meters, which is useless for lawn mowing. RTK solves this by pairing a mobile rover unit (mounted on the mower) with a fixed base station that sits on your property. The base station locks onto the same satellite constellation, calculates its own known position, and broadcasts correction data over a local radio link—typically at 2.4 GHz or LoRa frequencies—so the rover can cancel out common atmospheric and clock errors. The result is centimeter-level accuracy, typically 10 to 25 millimeters, which is more than sufficient to follow a precise mowing grid without overlapping or leaving strips.
Critically, RTK mowers do not require a buried wire. You define the mowing boundary digitally, either by walking the mower around the perimeter once or by drawing a polygon in the companion app. The base station must remain stationary and powered, and it needs a reasonably clear view of the sky. If you have a large, open property, RTK is the most flexible option because reconfiguring the boundary is a software operation rather than a physical excavation. However, RTK performance degrades near tall structures, dense tree canopies, and steep terrain, where satellite lock can be lost. Many systems handle this with an inertial measurement unit (IMU) that dead-reckons through short signal gaps, but prolonged occlusion still causes the mower to pause or return to its dock.
Because RTK relies on radio correction links, it shares some engineering principles with other wireless navigation systems. For example, the way an RTK base station and rover synchronize via a local radio channel is conceptually similar to how bandwidth and navigation protocols manage data integrity over a shared medium. Signal timing, error correction, and retransmission logic all matter in both contexts.
RTK-GPS vs Vision-AI vs Boundary Wire: Head-to-Head Diagnostic Comparison
| Parameter | RTK-GPS | Vision-AI (Camera) | Boundary Wire |
|---|---|---|---|
| Positioning accuracy | 1–2.5 cm (with base station) | 5–15 cm (mapped, scene-dependent) | ~5 cm (wire proximity) |
| Installation effort | Low–medium (base station setup) | Low (initial mapping drive) | High (trenching / stapling cable) |
| Boundary reconfiguration | Software-only (instant) | Software-only (remap) | Physical re-lay of wire |
| Obstacle detection | Ultrasonic + bump sensors | Camera + neural network | Bump sensors only |
| Performance under dense canopy | Degrades (satellite occlusion) | Good (no sky dependency) | Excellent (no sky dependency) |
| Performance in open fields | Excellent | Good (sun glare can confuse) | Good |
| Worst-case failure mode | Signal loss u2192 mower stops | Camera misclassification | Cable break u2192 total stop |
| Typical mowing pattern | Grid / spiral (planned) | Grid / adaptive (learned) | Random / spiral (coarse) |
| Compute requirements | Low (GPS + IMU fusion) | High (edge AI inference) | Minimal (loop detection) |
| Base station required | Yes (fixed, powered) | No | No (wire is reference) |
| Multiple-zone support | Excellent (digital zones) | Good (mapped zones) | Fair (wire routing) |
| Susceptibility to interference | Radio jamming, multipath | Lighting, shadows, rain | Electrical noise, corrosion |
| Recovery after power loss | Re-acquire satellite lock | Re-localize in map | Immediate (wire always live) |
| Typical price range (2026) | $1,400 – $4,500 | $1,800 – $5,000 | $700 – $2,500 |
| Best use case | Open yards, large lawns | Complex, obstacle-dense gardens | Budget, shaded, enclosed lawns |
The table above highlights a critical trade-off: no single system wins on every axis. RTK offers the best raw positioning accuracy and the least installation friction, but it is the only architecture with a hard dependency on satellite visibility. Vision-AI is the most obstacle-aware but carries the highest compute load and the most environmental fragility. Boundary wire is the most robust and cheapest but sacrifices flexibility and mowing-pattern quality. Your property’s specific constraints—canopy cover, yard geometry, budget, and tolerance for reconfiguration effort—should drive the decision, not marketing buzzwords.
How Vision-AI Mowers Map and Navigate
Vision-AI mowers replace satellite positioning with onboard cameras and a neural network that performs visual odometry and semantic scene understanding. During an initial mapping pass, the mower records a continuous video stream of the yard, and the onboard processor extracts visual landmarks—fence posts, tree trunks, flower beds, and lawn edges—to build a persistent topological map. On subsequent runs, the mower matches its live camera feed against this stored map to estimate its position. This is the same simultaneous localization and mapping (SLAM) approach used in robot vacuums and autonomous vehicles, scaled down to a lawn-mowing form factor.
The neural network also classifies objects in real time. A well-trained Vision-AI mower can distinguish a flower bed from a patch of grass, recognize a pet’s water bowl, and identify a child’s toy as an obstacle to avoid rather than a ground feature to mow over. This semantic understanding is the system’s biggest advantage: it can adapt its path on the fly when new obstacles appear, without any wire or boundary reconfiguration. In practice, this makes Vision-AI the strongest choice for irregular, heavily landscaped yards with many fixed and transient obstacles.
The downside is computational and environmental. These mowers run continuous on-device inference, which draws more power, generates more heat, and demands more sophisticated firmware. Like any computing system, their reliability depends heavily on the quality of the software stack. When a Vision-AI mower misbehaves—say, it fails to re-localize after being moved or crashes mid-run—the fix often involves reinstalling or updating the firmware. This is a domain where firmware and software recovery techniques become genuinely relevant, since a clean reflash of the navigation software frequently restores a confused mower to working order.
Vision-AI also has a notable Achilles’ heel: its dependence on visual conditions. Heavy rain, low sun glare, deep shadows, and even a thick layer of pollen can confuse the camera and degrade localization accuracy. Some flagships mitigate this with a secondary ultrasonic sensor suite or an IMU for short-range dead reckoning, but a purely camera-based system will always be at the mercy of lighting and weather more than its satellite-based or wire-based counterparts.
Boundary Wire: The Dependable Baseline
Boundary-wire systems are the oldest and most proven architecture, and they remain enormously popular for good reasons. A low-voltage wire is buried just beneath the soil surface around the perimeter of the mowing area, and the mower’s charging dock sends a pulsed AC signal through it. The mower carries a coil that senses the magnetic field generated by the current, allowing it to detect the boundary and stay inside the defined zone. Because the system relies on a physical, continuously energized loop rather than satellite or camera input, it is immune to canopy cover, weather, and lighting.
Installation is the primary cost. Laying a boundary wire requires either trenching or stapling the cable into the ground across the entire perimeter, and you must also create “islands” around obstacles like trees, flower beds, and ponds. This is physically demanding work, and for a large or irregular property it can take a full day or more. The trade-off is reliability: once the wire is laid, the mower will run year after year with minimal intervention, provided the cable is not severed by digging or ground movement.
Boundary-wire mowers are also the least flexible. Changing the mowing area means physically re-laying wire, and most budget models use a coarse random or spiral mowing pattern rather than a precise grid, which can leave visible striping inconsistencies on large lawns. However, for small, enclosed, heavily shaded yards—where RTK struggles with satellite lock and Vision-AI struggles with low light—a wire system is often the most dependable choice. It is also the easiest to repair: a broken wire can usually be located with a signal tracer and spliced back together. Regular inspection of the cable and connections is a core part of preventative equipment maintenance, since corrosion and mechanical stress are the two leading causes of wire-system failure.
Mowing Pattern Quality and Yard Coverage
Mowing pattern quality is where the three architectures diverge most visibly in practical terms. RTK mowers plan deterministic grid or spiral paths based on their precise position, so they cover the lawn systematically with minimal overlap and no missed strips. Vision-AI mowers can also plan structured patterns, but the quality depends on how confidently the system localizes itself at any given moment; in a difficult visual region, the mower may revert to a more conservative, less efficient path. Boundary-wire mowers, especially budget models, frequently use random bounce navigation, which eventually covers the lawn but is inefficient and can leave uneven wear on heavily trafficked areas.
For large, open lawns, RTK’s deterministic coverage is a decisive advantage. A systematic grid produces an even, professional-looking cut and finishes the job faster than random navigation. For complex yards, Vision-AI’s adaptive planning wins because it can route around obstacles intelligently rather than bouncing off them. And for small, simple, enclosed lawns, even a random-pattern wire mower will achieve acceptable coverage, making the extra cost of RTK or Vision-AI hard to justify.
Signal Integrity, Interference, and Environmental Limits
Every navigation architecture has a distinct set of failure modes tied to its physical medium, and understanding these is essential for a realistic purchase decision. RTK systems depend on two wireless links: the satellite constellation and the local base-station radio. Both are susceptible to interference. Multipath reflection off buildings and fences can corrupt satellite measurements, while the correction link can be disturbed by other 2.4 GHz devices. Some RTK mowers also struggle in urban canyons where sky visibility is partially blocked. The IMU provides a short grace period, but sustained signal loss forces the mower to stop safely and wait for reacquisition.
Vision-AI systems fail differently. Their camera feeds are degraded by adverse lighting and weather, and their neural networks can occasionally misclassify objects—treating a patch of shadow as an obstacle or, worse, failing to recognize a real obstacle. These errors are usually non-catastrophic because bump sensors provide a fallback, but they reduce efficiency and can occasionally cause the mower to stall. Boundary-wire systems are the most immune to environmental interference, but they have their own failure mode: a severed cable or a corroded connection kills navigation entirely, and the mower will not operate until the wire is repaired.
All three architectures ultimately depend on the same underlying principle: reliable signal processing and error correction. The way these systems handle timing, retransmission, and data integrity mirrors the fundamentals of processor bus architecture, where clock synchronization and data-path integrity determine overall system reliability. A mower is, after all, a small embedded computer on wheels, and its navigation quality is bounded by how cleanly its sensors and processors exchange data.
Total Cost of Ownership and Maintenance
Purchase price is only the beginning. Boundary-wire systems carry a significant one-time installation cost that is frequently underestimated, especially for irregular lots. RTK systems shift that cost to the base station—a permanent fixture that must be mounted, powered, and occasionally repositioned if you move. Vision-AI systems have the lowest installation cost but the highest ongoing compute and power demands, and their cameras need periodic cleaning to maintain localization accuracy. Over a five-year ownership horizon, the total cost of ownership often converges more than the sticker prices suggest.
Batteries, blades, and sensors wear out on all three systems and follow similar replacement cycles. Blade sharpening and replacement are universal, and wheel and chassis maintenance is comparable. The differentiating maintenance items are the navigation-specific components: RTK base-station antennas and radio modules, Vision-AI camera lenses and compute modules, and boundary-wire cables and splices. Each requires a different skill set to service, and this is another reason to consider the broader ecosystem of electronics thermal management—a mower’s navigation computer, like any embedded processor, runs more reliably when its thermal design is sound and its cooling vents are kept clear of grass clippings and debris.
Recommendations by Scenario
For a large, open lawn with good satellite visibility and a desire for precise, systematic coverage, an RTK mower is the clear winner. It offers the best accuracy, the least installation friction, and the easiest boundary reconfiguration. Choose a model with a robust IMU and a base station that supports multiple zones if you have separated lawn areas. The Husqvarna EPOS RTK Navigation Whitepaper is an authoritative technical reference that explains the correction-link architecture and accuracy claims in detail, and it is well worth reading before committing to a specific RTK vendor.
For a complex, obstacle-dense garden with many flower beds, trees, and walkways, a Vision-AI mower is the strongest choice. Its semantic object recognition lets it adapt to a changing yard without any physical boundary work, and it is the only architecture that genuinely handles transient obstacles intelligently. Be prepared for higher power draw, more frequent firmware updates, and some sensitivity to lighting conditions.
For a budget-conscious buyer with a small, shaded, enclosed lawn, a boundary-wire mower remains the most sensible option. It is the cheapest to buy, the most robust against environmental conditions, and entirely adequate for modest coverage needs. Accept the installation effort and the coarse mowing pattern, and you will get dependable service for years with minimal ongoing cost.
Future Trends: Hybrid Navigation
The most advanced 2026 flagships are moving toward hybrid systems that fuse two or more of these architectures. RTK-plus-Vision hybrids use satellite positioning for global accuracy and cameras for obstacle avoidance and short-range localization, combining the strengths of both while mitigating their individual weaknesses. These hybrids are more expensive and more complex, but they represent the direction the market is heading, and early field tests show dramatically better reliability in challenging environments than any single-architecture system.
Whether a hybrid is worth the premium depends on your property’s specific challenges. If you have a large open lawn with a few obstacle-dense areas, a hybrid may be overkill—a good RTK mower with ultrasonic sensors will suffice. If your yard is uniformly complex and shaded, a hybrid’s ability to fall back to camera-based navigation during satellite loss is a genuine advantage. As with any technology purchase, the deciding factor should be a realistic assessment of your actual mowing conditions rather than the appeal of the newest feature set.